Projects
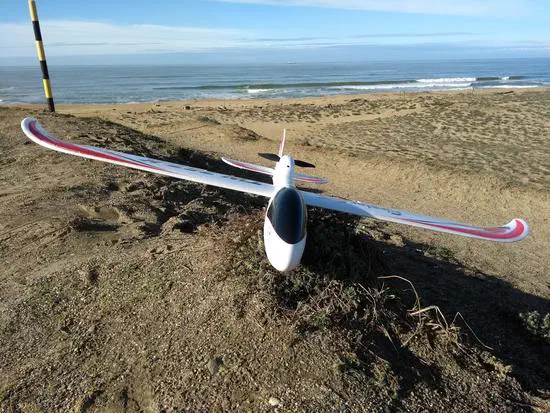
Fixed-wing autopilot based on Simulink model
16-bits fixed-wing autopilot Model Based Design
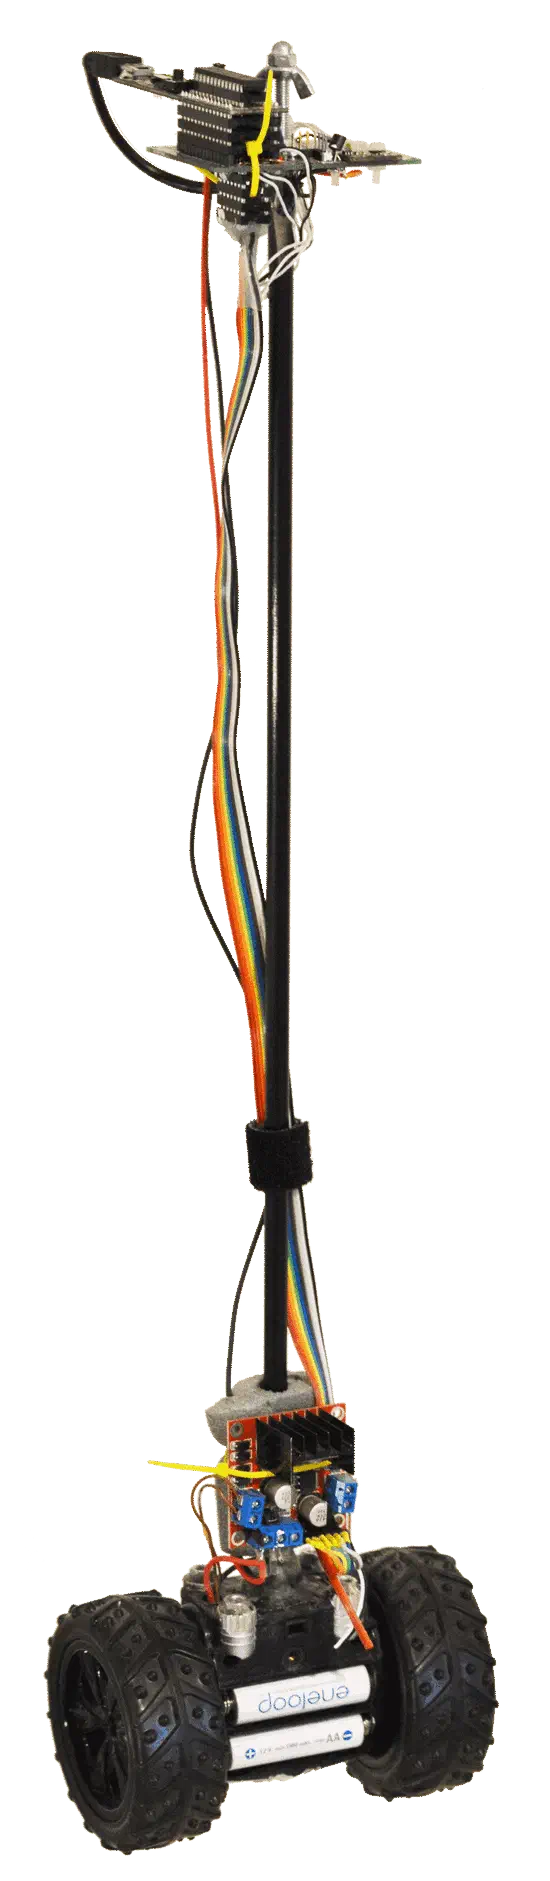
Inverted Pendulum
Inverted pendulum running on a microstick II dsPIC board. An IMU algorithm estimate the angle based on a MEMS inertial sensor. LQR feedback controls the DC motors of the trolley. No encoder are used.
Lab INSA - Real Time Control for a DC / PMSM Motors
Simulation & real-time control of a motor with MCLV 2 board
Old website
rapid control prototyping experiments (2006-2011) with dsPIC. Former blockset, website and forum.
Recent Posts
Embedded systems require programming skills and an important set-up effort. Control algorithm is typically implemented last with a PI feedback loop. However control theory provides many solutions to explore improving systems dynamic responses, perturbation rejection and robustness to model mismatch.
Interested in applied math, a blockset for Matlab/Simulink targeting dsPIC microcontrollers was developed in 2005. It enables focusing on the controller part using Simulink simulation rather than on implementation problems. Rapid Control Prototyping (RCP) became possible on any dsPIC based board. It is embedded on cheap demo or custom board and does not require budget to acquire high-end tools like dSPACE, SpeedGoat, National Instrument alternative.
$$ \text{One push button} \left\{ \begin{array}{l} \text{- Generate C code} \\\ \text{- Compile} \\\ \text{- Upload & Run on the target} \end{array} \right. $$
This dsPIC Target toolbox was used for a PhD thesis on bio-robotics from 2006 to 2009. It shortens the path from the visual signal processing simulation and control of our aerial robot and replaced the original dSPACE platform in our lab.
The same approach was then used to develop data fusion algorithm on motion analysis in wearable sports article at MOVEA in 2010-2011.
Joining Microchip Technology in 2011 allowed the development of the MPLAB blockset. The toolbox initially targeted dsPIC and was extended to:
- dsPIC33A
- PIC32 (MIPS core)
- SAMx2 (ARM Cortex M0+)
- SAMx5 (ARM Cortex M4)
- SAMx7 (ARM Cortex M7)
We implemented a rate-monotonic scheduler (multitasking system) and integrates completely with the MathWorks environment with support for PIL (Processor In the Loop) and External Mode.
The toolbox now targets up to 650 chips. The development and support tasks were split in 2022. Current efforts focus on new dsPIC developments and support.
For company, scientists, and students, rapid prototyping enables focusing on ideas rather than getting lost in the details of embedded programming. Shortening the loopback $Simulation \Leftrightarrow Hardware $ allows you to
- refine and validate a model thanks to early test
- develop controller using the system digital twin
- implement the final controller
- benefit from the wide MathWorks tools available
Electronics projects from this website use the Microchip blockset. Older projects are available on the old website.
- Control Theory & applied math
- Embedded system
- Swimming
Ph.D Automatic, Signal Processing & Aerial Robotics, 2009
National Center for Scientific Research (CNRS) / University Montpellier II
Master of Research - Signal Processing and Digital Communication, 2004
University of Nice Sophia-Antipolis
Engineer - System on Chip, 2004
ESIEE Paris
Experience
Ph.D research on visual and micro-aerial vehicle adapted control laws within the Biorobotics Laboratory, Institute of Movement Science, National Center for Scientific Research, at the University of Aix-Marseille. Realisation of a 100g aerial robot endowed with a visuo-inertial guiding system.
- Electronic design (microcontrollers, sensors, numerical buses)
- Signal processing & automatic : Identification of robot’s dynamics ; control loop; visual sensor & guidance systems; fixed point.
Electronics :
- Design and realisation of an electronic board (sensor, signal processing, data transmission) for measuring human head’s 3D acceleration.
- Design and realization of a miniature vestibular implant for small mammal.
Applied math : Linear Analysis (PCA, LDA) to extract relevant information from large measurement database. Script to generate automatic report through MATLAB and LaTeX.
Contact
- lubin@kerhuel.eu
-
19 rue Adrien Barthe
64100 Bayonne - Microchip Forum